Ikhyeon Cho
Ph.D. Candidate
Expected Feb 2027
I am a Ph.D. candidate in Mechanical Engineering at Korea University, where I also earned my B.S.Advised by Prof. Woojin Chung, I've been fortunate to lead several collaborative research projects with industry partners, including Hyundai Motor Group's Robotics LAB and L Project Team, as well as Hyundai Mobis.
Research
My research aims to advance robotic intelligence that evolves through experience, with an emphasis on the following areas:
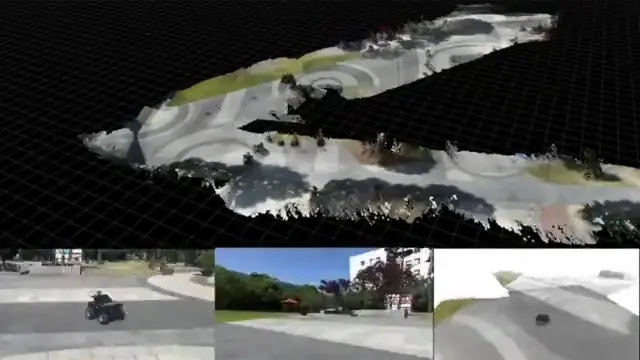
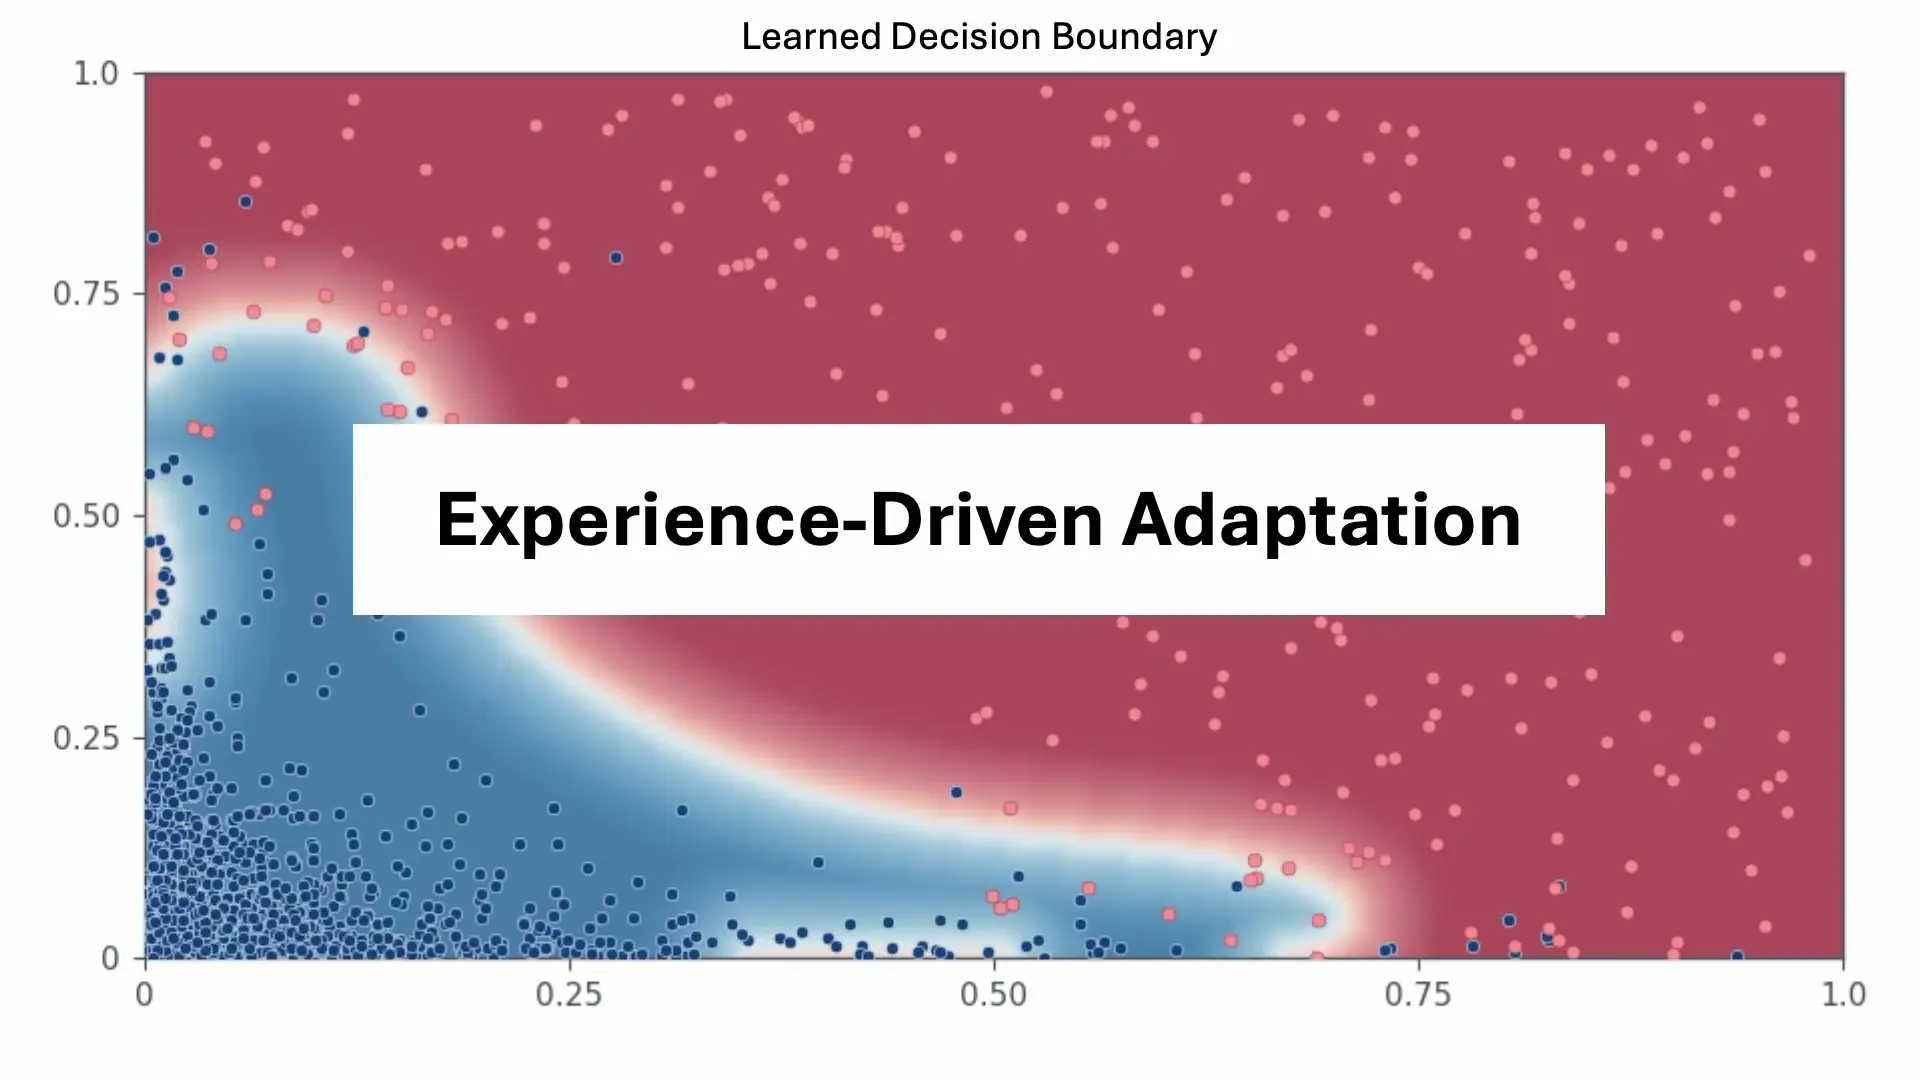
Online Self-Supervised Learning
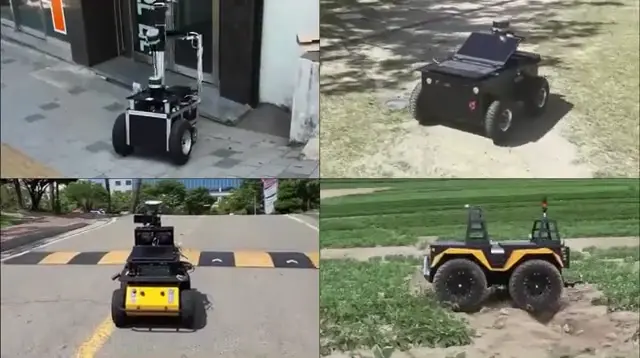
Perceptive Navigation
Looking ahead, I am interested in embodied robot learning—how robots learn and adapt task-driven behaviors through physical interaction.
Publications & Preprints
Terrablox: Evidential Persistence Reasoning for Robot-Centric Elevation Mapping in Dynamic Urban Environments
IEEE Robotics and Automation Letters (RA-L)Under Review
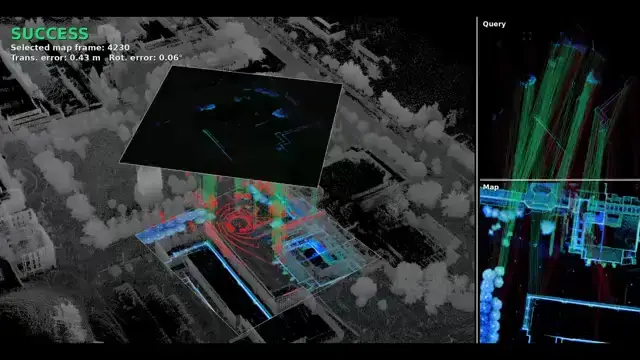
MapGLoc: Robust LiDAR Global Localization on Dense 3D Maps for Mobile Robots
IEEE Robotics and Automation Letters (RA-L)Under Review
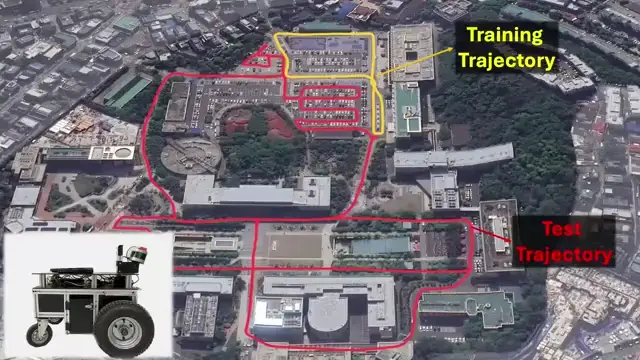
Learning Self-Supervised Traversability With Navigation Experiences of Mobile Robots: A Risk-Aware Self-Training Approach
IEEE Robotics and Automation Letters (RA-L), 2024
Open-Source Software
FastDEM Official Implementation
Fast elevation mapping engine for embedded robots — 100+ Hz on Jetson Orin.
TraverseSet: A LiDAR-inertial dataset for traversability learning
LiDAR, IMU, and odometry data from urban and rural environments.
Selected Projects
- Project Lead
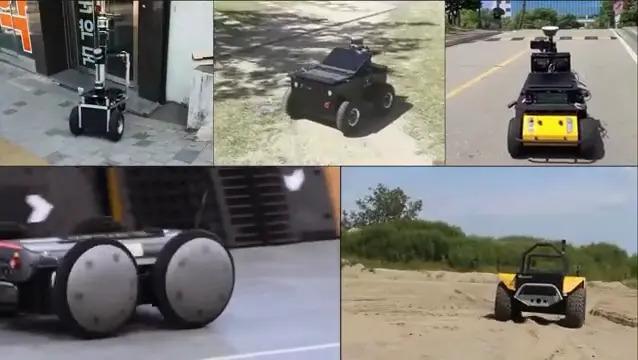
Learning Robot-Specific Traversability from Navigation Experience
Description
Learns robot-specific traversability through online self-supervision from short driving demonstrations.
- Project Lead
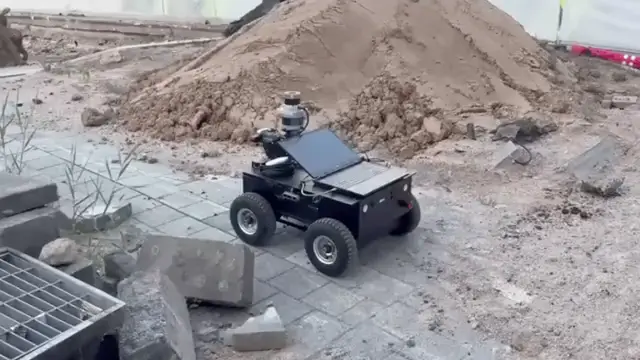
Real-Time Mapping for Robotic Exploration in Rough Terrain
Description
Performs online terrain mapping using LiDAR or RGB-D data for autonomous exploration on resource-constrained robots.
- Project Lead
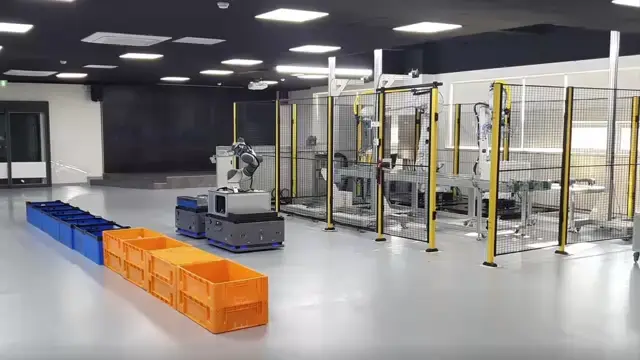
Multi-Robot Perception and Navigation in Dynamic Factory Environments
Description
Coordinates multi-robot navigation around unexpected obstacles using camera–LiDAR perception, shared obstacle tracking, and adaptive replanning.
- Project Co-Lead
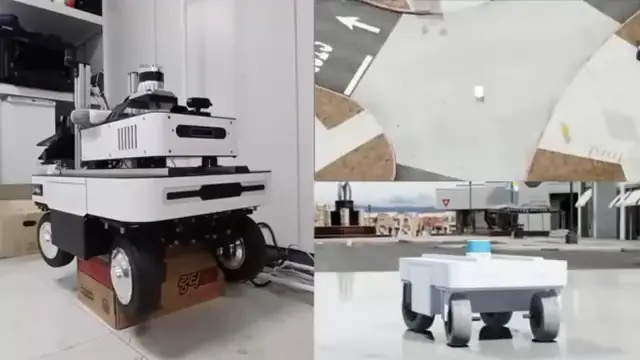
Robot-in-the-Loop Simulation for Autonomous Navigation
Description
Connects physical robot hardware with Isaac Sim to evaluate autonomous navigation consistently across robot platforms and software stacks.